Dynamics · Control · Intelligence

Research at DyCoAI

From Mathematical Foundations to Reliable Autonomous and Networked Systems

Our research connects dynamical systems, operator theory, information flow, and control with the challenges of autonomy and interconnected infrastructure. We develop mathematical foundations and data-driven computational methods, then investigate their application to robotics, energy systems, and cyber-physical networks.

Mathematical foundations

Foundational Research

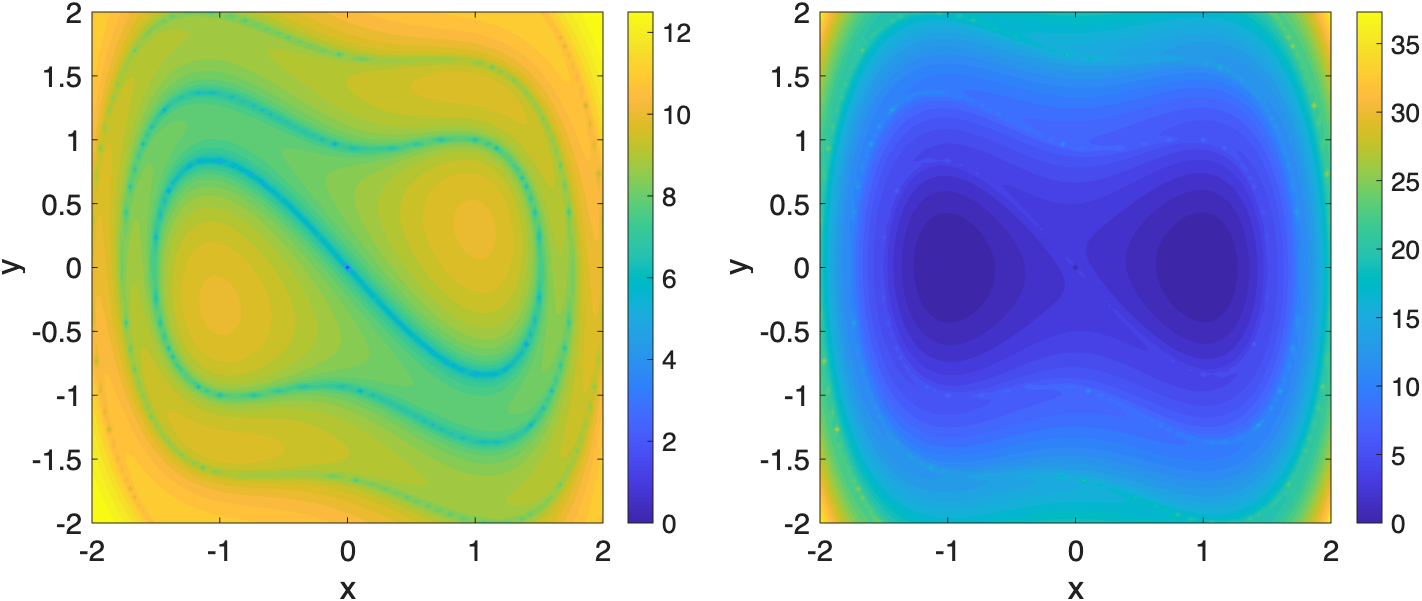
Network diagrams, information-response patterns, and a control framework for shaping information flow

Information Flow and Control Over Networks

We quantify causal influence in dynamical networks and study how topology shapes information transfer. Our methods combine ergodic theory, stochastic dynamics, and control to analyze and regulate network interactions.

Explore Research

From foundations to practice

Application Research

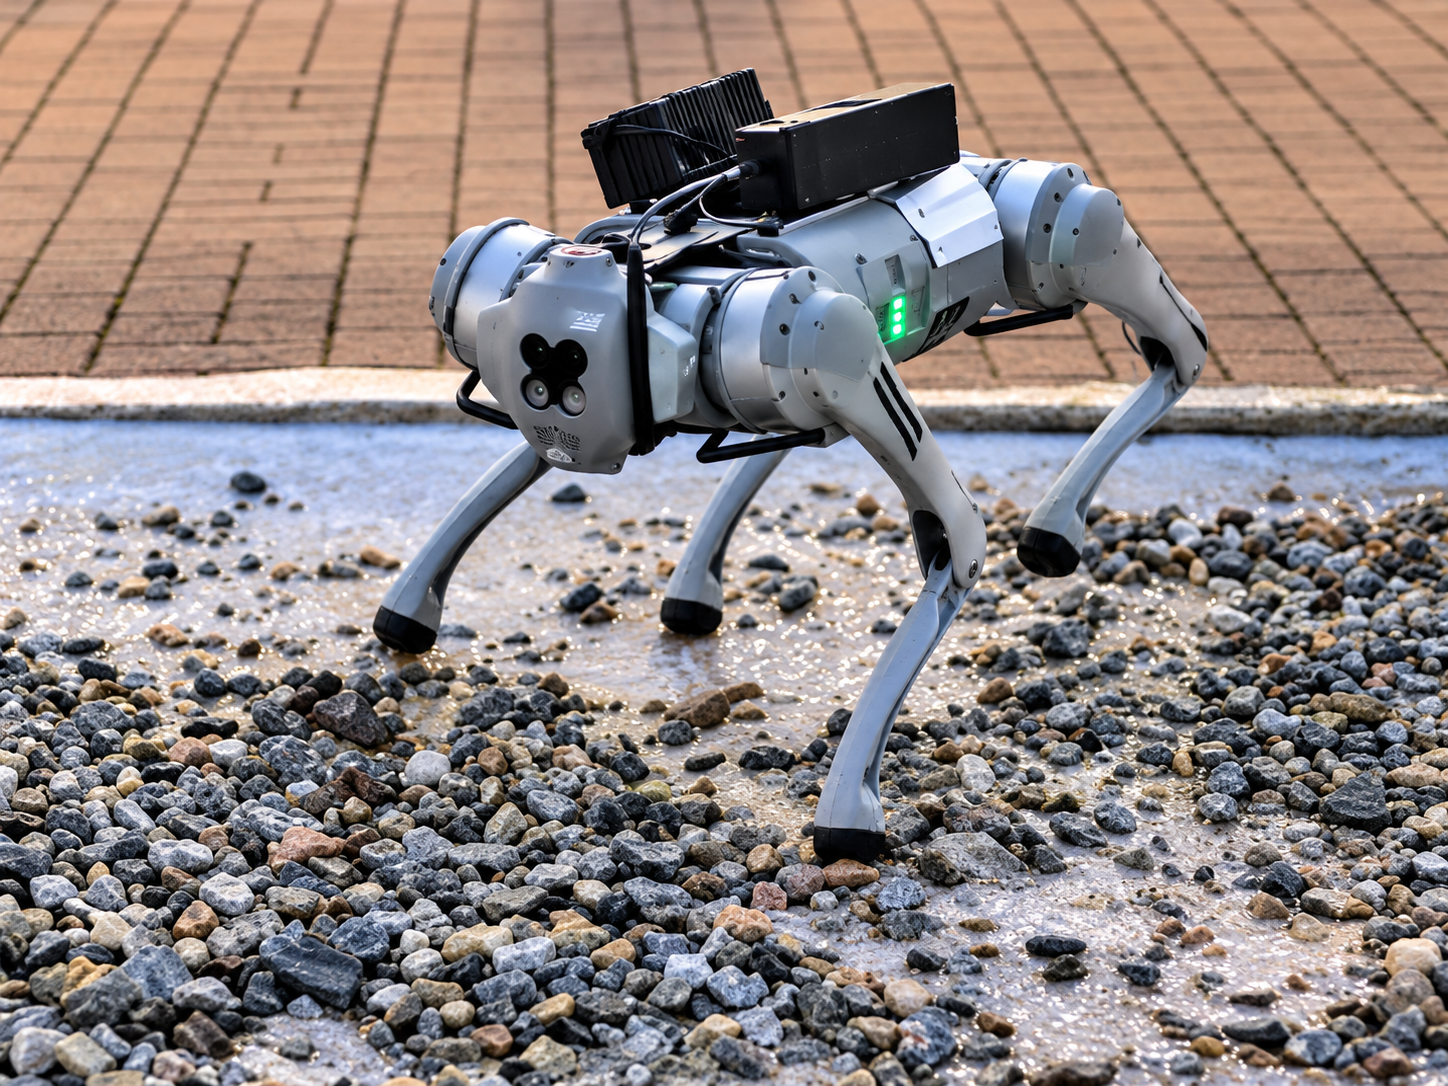
A quadruped robot walking across wet gravel

Off-road Autonomy and Robotics

We develop terrain-aware models, safety-constrained planning, and Koopman-based model predictive control for wheeled vehicles and quadruped robots navigating challenging environments.

Explore Research
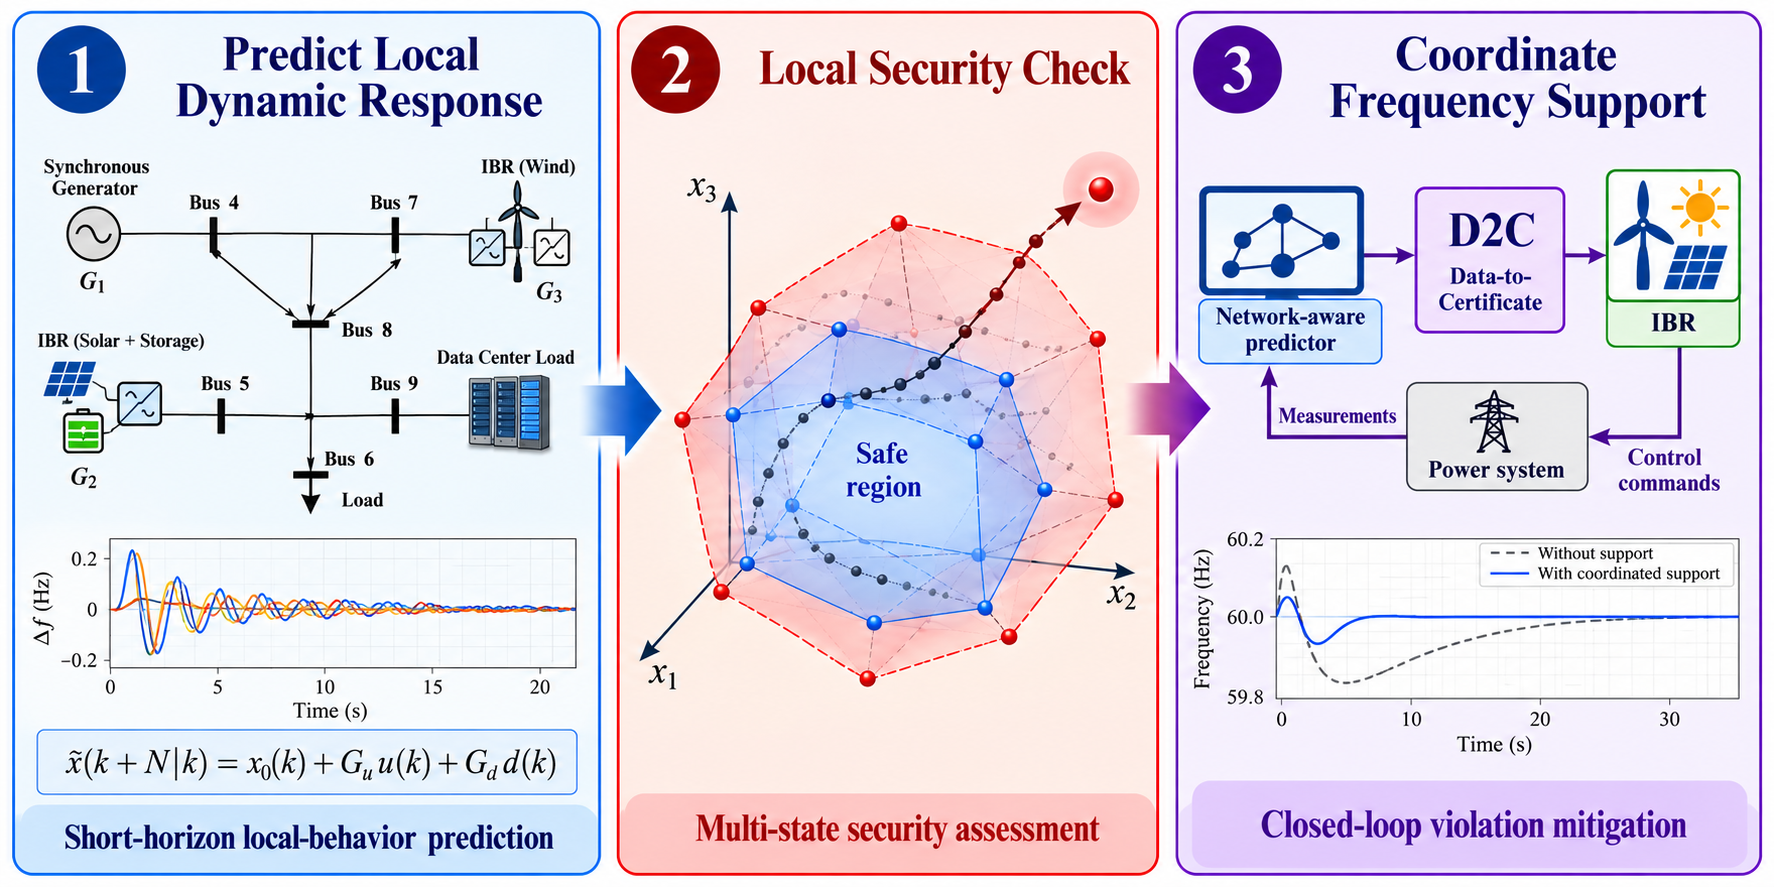
Power-system workflow connecting local dynamic prediction, security assessment, and coordinated frequency support

Power and Energy Systems

Using phasor measurement unit data and operator-theoretic models, we study grid stability, uncertainty from renewable generation, robust optimal power flow, and distributed voltage control.

Explore Research
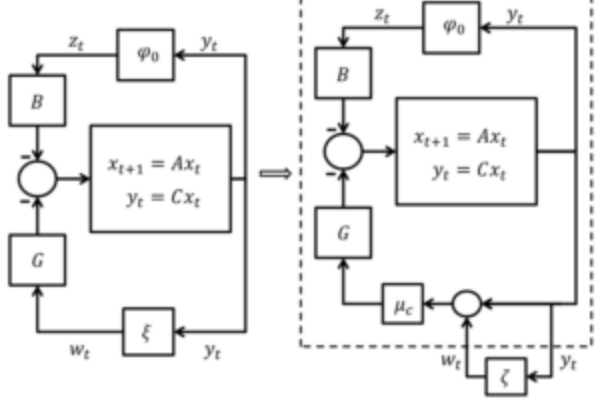
Feedback block diagrams for a networked dynamical system with communication uncertainty

Cyber-Physical Systems

We investigate estimation and stabilization over uncertain communication channels, robust synchronization, and distributed optimization, connecting system dynamics and network topology to achievable performance.

Explore Research